Robotics & control engineering
Robotics consulting for robot integration, real-time controls, motion, sensor fusion, and the software connecting physical systems.
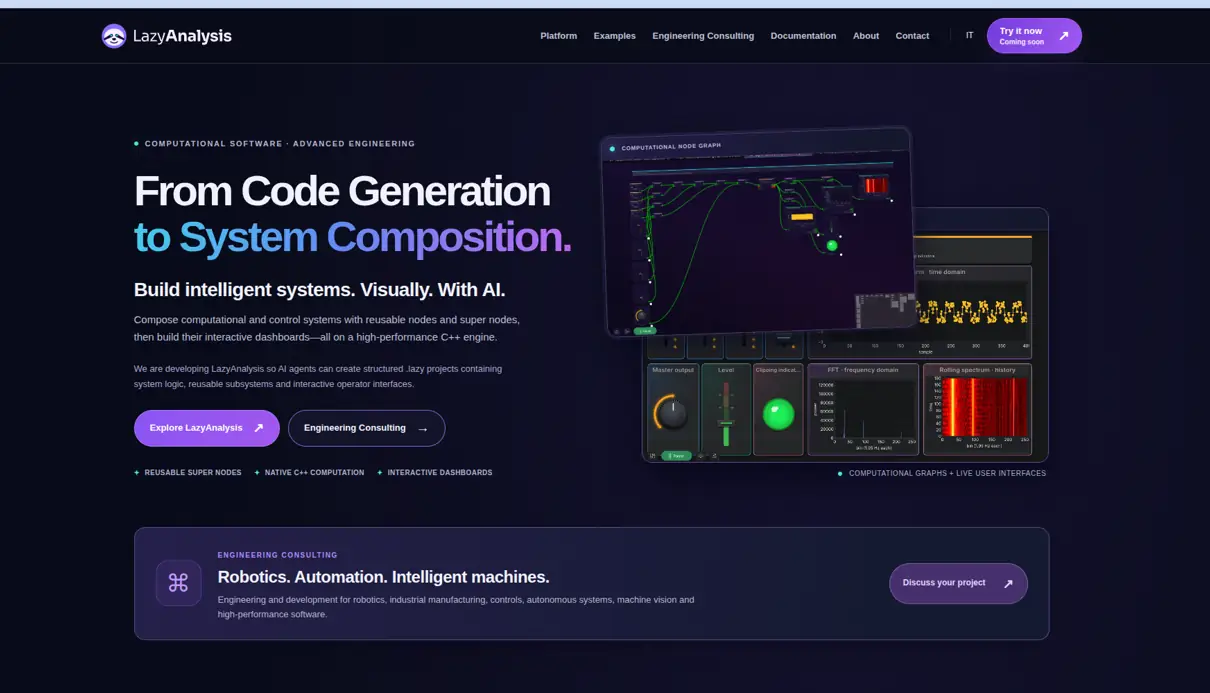
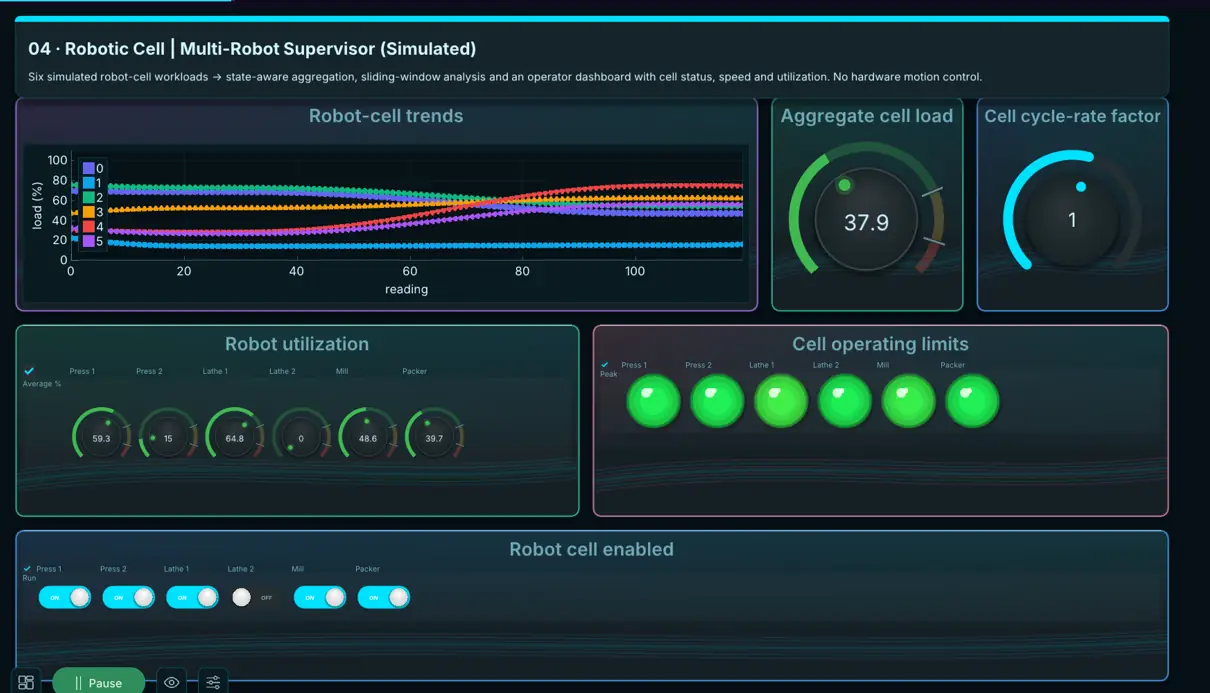
These are screenshots of running LazyAnalysis simulations, not footage of deployed industrial equipment. Engineering consulting is available independently of the platform.
Make the robot work as part of the system
A robot rarely works alone. It must exchange data with sensors, tools, supervisory software, and other equipment. LazyAnalysis S.r.l. helps design those interfaces and the software around them, with attention to timing, coordinate frames, units, and operating modes.
Controls that match the physical problem
Support can include control-system modeling, nonlinear control design, motion-related software, and analysis of system behavior. We start with the plant, sensors, actuators, and performance objectives. Sampling rates, delays, saturation, and disturbances are part of the engineering problem.
From integration to validation
Typical work may include robot-interface software, sensor alignment, data synchronization, test tools, or a prototype control pipeline. Validation criteria can cover tracking behavior, latency, data consistency, and handling of missing measurements. Project-specific safety requirements and operational responsibilities must be defined with the client; no certification is implied.
What to bring to the first discussion
Share the robot and controller models, available interfaces, sensor types, target update rates, existing software, and the behavior you want to improve. We can then identify whether a focused integration task, architecture review, or broader development engagement is appropriate.
Industrial automation
Inspection pipelines, industrial sensing, data acquisition, and operator tools.
↗Engineering ConsultingPhysical AI & autonomous systems
Sensors, perception, control software, and AI integration for physical systems.
↗Engineering ConsultingHigh-performance software
C++ and Python, concurrency, low-latency processing, and distributed computation.
↗